
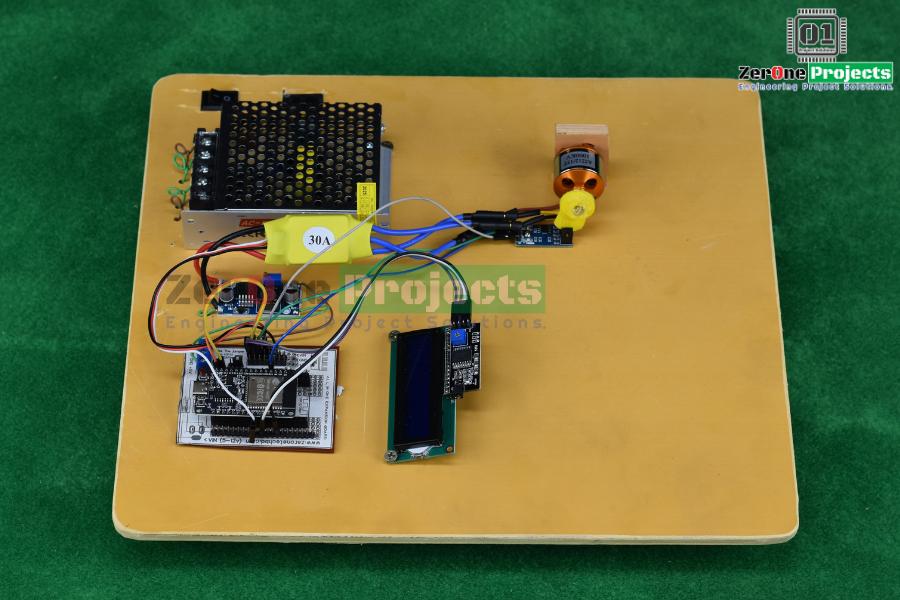
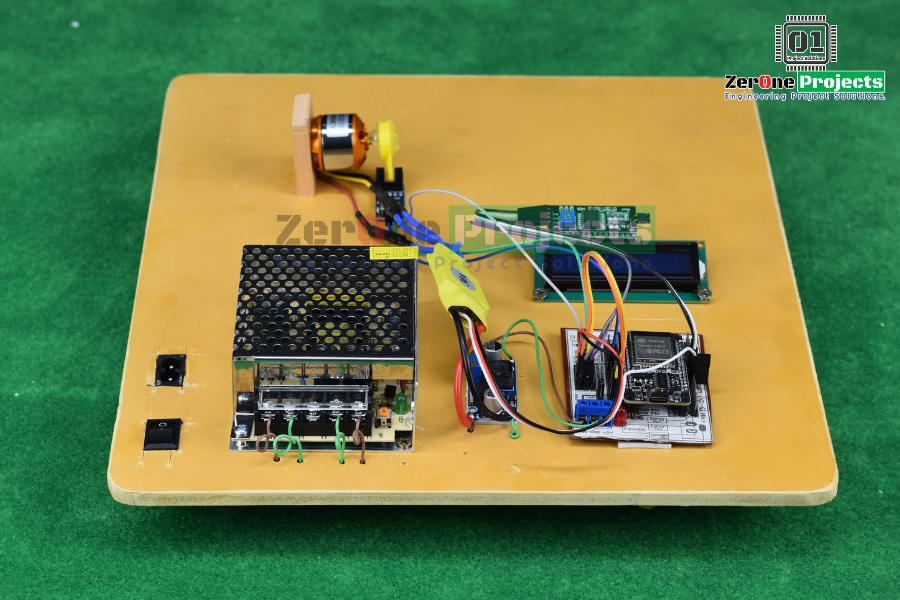
BLDC motor rpm control with pid controller and sliding mode controller
Project Fee:Negotiable
Project Discount:0
Project Duration:7 Days
BLDC motor rpm control with pid controller and sliding mode controller
The BLDC Motor RPM Control System is designed to regulate motor speed using two control techniques: Proportional–Integral–Derivative (PID) control and Sliding Mode Control (SMC). The system measures the motor's rotational speed and adjusts the control signal to maintain the desired RPM under varying load conditions. By comparing both methods, the project evaluates speed accuracy, response time, and stability.
Control BLDC motor speed accurately.
Implement PID and Sliding Mode Controllers.
Maintain the desired RPM under changing loads.
Compare speed response and control performance.
Reduce speed error and improve stability.
Explore advanced motor control techniques.
Connect a BLDC motor to a suitable electronic speed controller (ESC).
Measure motor speed using a Hall-effect sensor or encoder.
Use a microcontroller to collect RPM feedback.
Implement PID and Sliding Mode Control algorithms.
Adjust the motor control signal according to the selected controller.
Record RPM, settling time, overshoot, and steady-state error.
Compare both controllers under different speed commands and load conditions.
BLDC Motor
Electronic Speed Controller (ESC)
Arduino Due or STM32 Controller
Hall-Effect Sensor or Rotary Encoder
PID Controller Algorithm
Sliding Mode Controller Algorithm
Motor Driver Circuit
LCD Display
Battery or DC Power Supply
Tachometer
Computer for Data Analysis
The BLDC motor rotates according to the control signal supplied by the ESC.
The speed sensor measures the actual RPM and sends feedback to the controller.
The desired RPM is compared with the measured RPM to calculate speed error.
The PID controller adjusts the control signal using proportional, integral, and derivative actions.
The Sliding Mode Controller uses a defined sliding surface and switching control law to reduce speed error and improve robustness against disturbances.
Both controllers are tested under similar operating conditions to compare speed tracking, response time, overshoot, and disturbance rejection.
Accurate RPM regulation
Improved speed stability
PID and SMC performance comparison
Better load disturbance handling
Reduced steady-state error
Practical motor control research
The BLDC Motor RPM Control System demonstrates the application of PID and Sliding Mode Control techniques for accurate motor speed regulation. By evaluating both controllers under different operating conditions, the project helps identify their strengths in speed tracking, stability, and disturbance rejection. The results can support the selection of suitable control methods for electric vehicles, robotics, industrial automation, and other BLDC motor applications.
🔰 ইঞ্জিনিয়ারিং ফাইনাল ইয়ার প্রজেক্টস এবং স্কুল-কলেজের ছাত্র ছাত্রীদের বিজ্ঞান মেলায় প্রতিযোগিতা করার জন্য, পছন্দের তালিকায় রাখতে পারেন আমাদের নিজিস্ব ডিজাইনের তৈরি এই ডেমো প্রজেক্ট গুলো। আমাদের রয়েছে সফলতার সাথে ১০০০+ প্রজেক্ট সম্পন্ন করার অভিজ্ঞতা।
🔰 আপনার প্রজেক্টের আইডিয়া, সম্পূর্ণ প্রজেক্ট, প্রজেক্ট পেপার, পাওয়ার পয়েন্ট প্রেজেন্টেশন এবং আপনার প্রজেক্ট ভাইবা পর্যন্ত সকল ধরণের কারেকশন, সহযোগিতা করার জন্য আমাদের টিম আছে আপনার সাথে।
🔰 প্রতিনিয়ত আমরা আপনাদের জন্য বেস্ট সার্ভিস আর আপনাদের চাহিদা অনুযায়ী প্রজেক্ট তৈরি করে আপনাদের হাতে পৌঁছে দেওয়ার জন্য করে যাচ্ছি অক্লান্ত পরিশ্রম। আপনাদের রেসপন্সে আমরা অভিভূত।
𝐂𝐨𝐧𝐭𝐚𝐜𝐭 𝐃𝐞𝐭𝐚𝐢𝐥𝐬:
📞 01894-801150, 01886-180101
📧Email: projects.zeronebd@gmail.com
🌐Web: https://www.projects.zeronebd.com
YouTube Channel: https://www.youtube.com/c/ZerOneProjects
Instagram: www.instagram.com/zerone_projects_bd
🏠অফিস:
প্লট-০৩, রোড -০৪, সেকশন ৬/ক
মিরপুর-২ (মিরপুর শের-ই-বাংলা স্টেডিয়ামের ৪নং গেটের বিপরীতে),
ঢাকা-১২১৬
Copyright ©2023 ZerOne IT Limited. All Rights Reserved.